Pursuing MS in Robotic Systems Development at Carnegie Mellon University
About Me
I'm Akshit Raizada, currently pursuing my Master's in Robotic Systems Development at Carnegie Mellon University. I completed my B.Tech in Mechanical Engineering at IIT Indore, where I developed a strong foundation in robotics, automation and AI.
Over the past few years, I've worked on projects spanning autonomous vehicles, multi-robot systems, computer vision and off-road navigation. I enjoy bridging research with real-world deployment, from perception stacks and sensor fusion pipelines to autonomous control and hardware integration.
I'm always excited to connect with people whether it's for collaboration, research or just sharing ideas.
Designed a self-supervised, real-time off-road motion planning system that learns traversability costmaps by fusing RGB, IR and vehicle velocity using image processing, homographic projection and Fourier features, eliminating manual labeling. Curated and released a large-scale multi-modal off-road dataset (multi-LiDAR, RGB, NIR, SLAM, odometry) across diverse terrain and conditions. Built a deployable perception stack benchmarked against SOTA semantic segmentation with domain adaptation for robustness across platforms and environments.
AutoMind Dynamics (Project Intern)
Designed and deployed a modular ROS-compatible Bird's Eye View perception framework for real-time 3D object detection via LiDAR-camera-radar fusion on compute-constrained hardware. Delivered a fully Dockerized, production-ready system integrated with Bharat Electronics Ltd.'s robotics stack, enabling downstream calibration, state estimation and navigation in real-world deployments.
CMU Course Projects
Humanoid LIPM Control: Implemented standing, recovery and walking controllers for humanoids using the Linear Inverted Pendulum Model (LIPM), including CoM/ZMP-based stabilization and step planning under disturbances.
Probabilistic Localization (EKF & PF): Implemented robot localization using Extended Kalman Filters and Particle Filters, modeling nonlinear dynamics, sensor noise and resampling, compared against graph-based methods.
Real-Time Target Catching Planner: Designed a real-time(1 second) planner for a long scale(5000×5000 grid) target catching using multi-source weighted backward A* in (x, y, t), guided by a backward Dijkstra heuristic with greedy fallbacks.
Path Tracking & Vehicle Models: Implemented kinematic bicycle and differential drive models with constraint-aware trajectory planning and feedback control for accurate path tracking.
Sampling-Based Motion Planning: Implemented from scratch and compared RRT, RRT-Connect, PRM, RRT* and RRT* w/t node rejection and goal biasing, analyzing convergence and solution quality.
Combined Task and Motion Planning: Built a TAMP framework integrating symbolic task planning with geometric motion planning via hierarchical decomposition and feasibility-aware backtracking.
Drone Control & Trajectory Optimization: Developed quadrotor control and trajectory pipelines using differential flatness, polynomial trajectory generation and cascaded PID/LQR-style controllers for stable tracking.
CO₂ Monitoring & ALPR
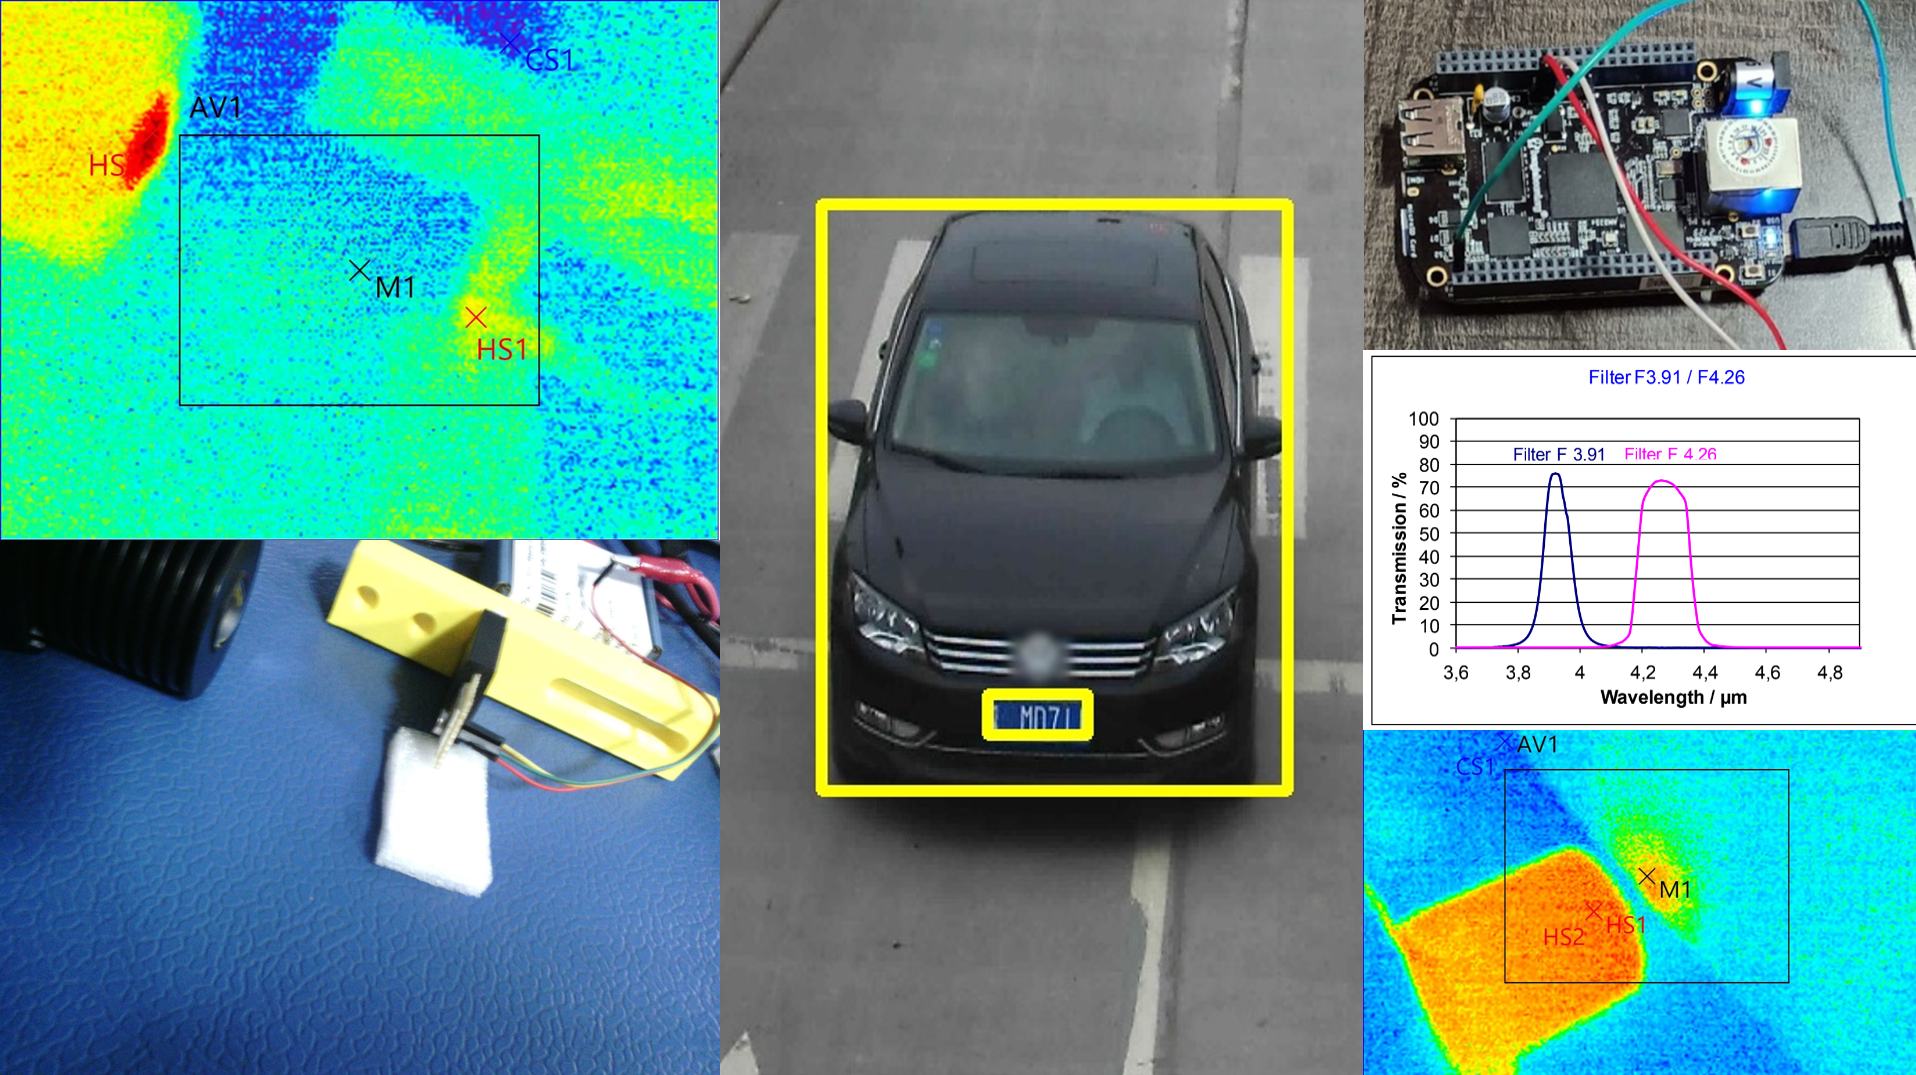
Developed an ALPR system using YOLOv9 and Tesseract OCR trained on a custom Indian license plate dataset, deployed on Raspberry Pi for accurate edge inference, earning the Chanakya UG Fellowship Grant 2023. Designed a through-beam IR-based CO₂ sensor and integrated cloud logging to flag violators based on emissions
Formation Control of MAVs
Developed a multi-threaded Python API for controlling multiple MAVs and created a robust PID-controlled multi-agent waypoint navigation algorithm with visual position feedback from ArUco markers. We were awarded the bronze medal at the Inter IIT Tech Meet 11.0 at IIT Kanpur for this project.
Greenhouse Harvesting Robot
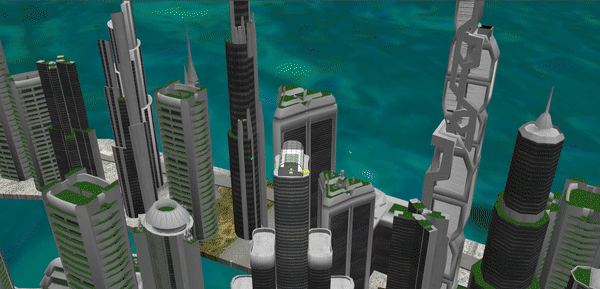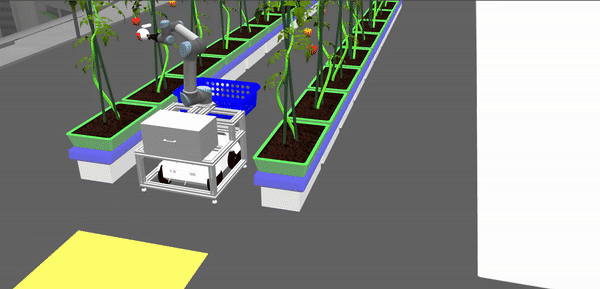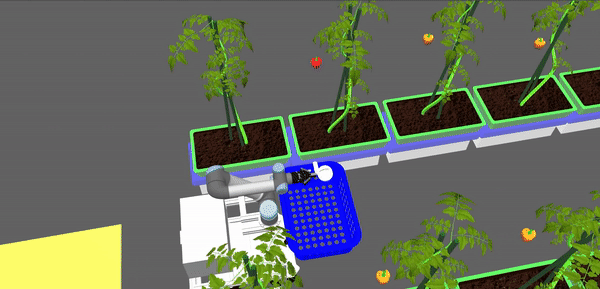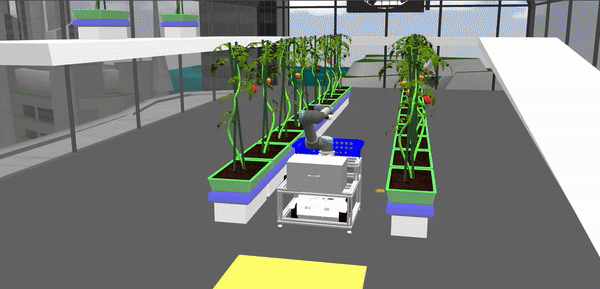
LiDAR UGV navigation + stereo vision for fruit detection. Motion planning with MoveIt for automated harvesting & sorting.
LiDAR-Based Dynamic Obstacle Avoidance
Integrated 3D SLAM, AMCL & LiDAR-based human detection with A* + TEB planners. Won 1st place at IITI Summer of Code.
Autonomous Race Car
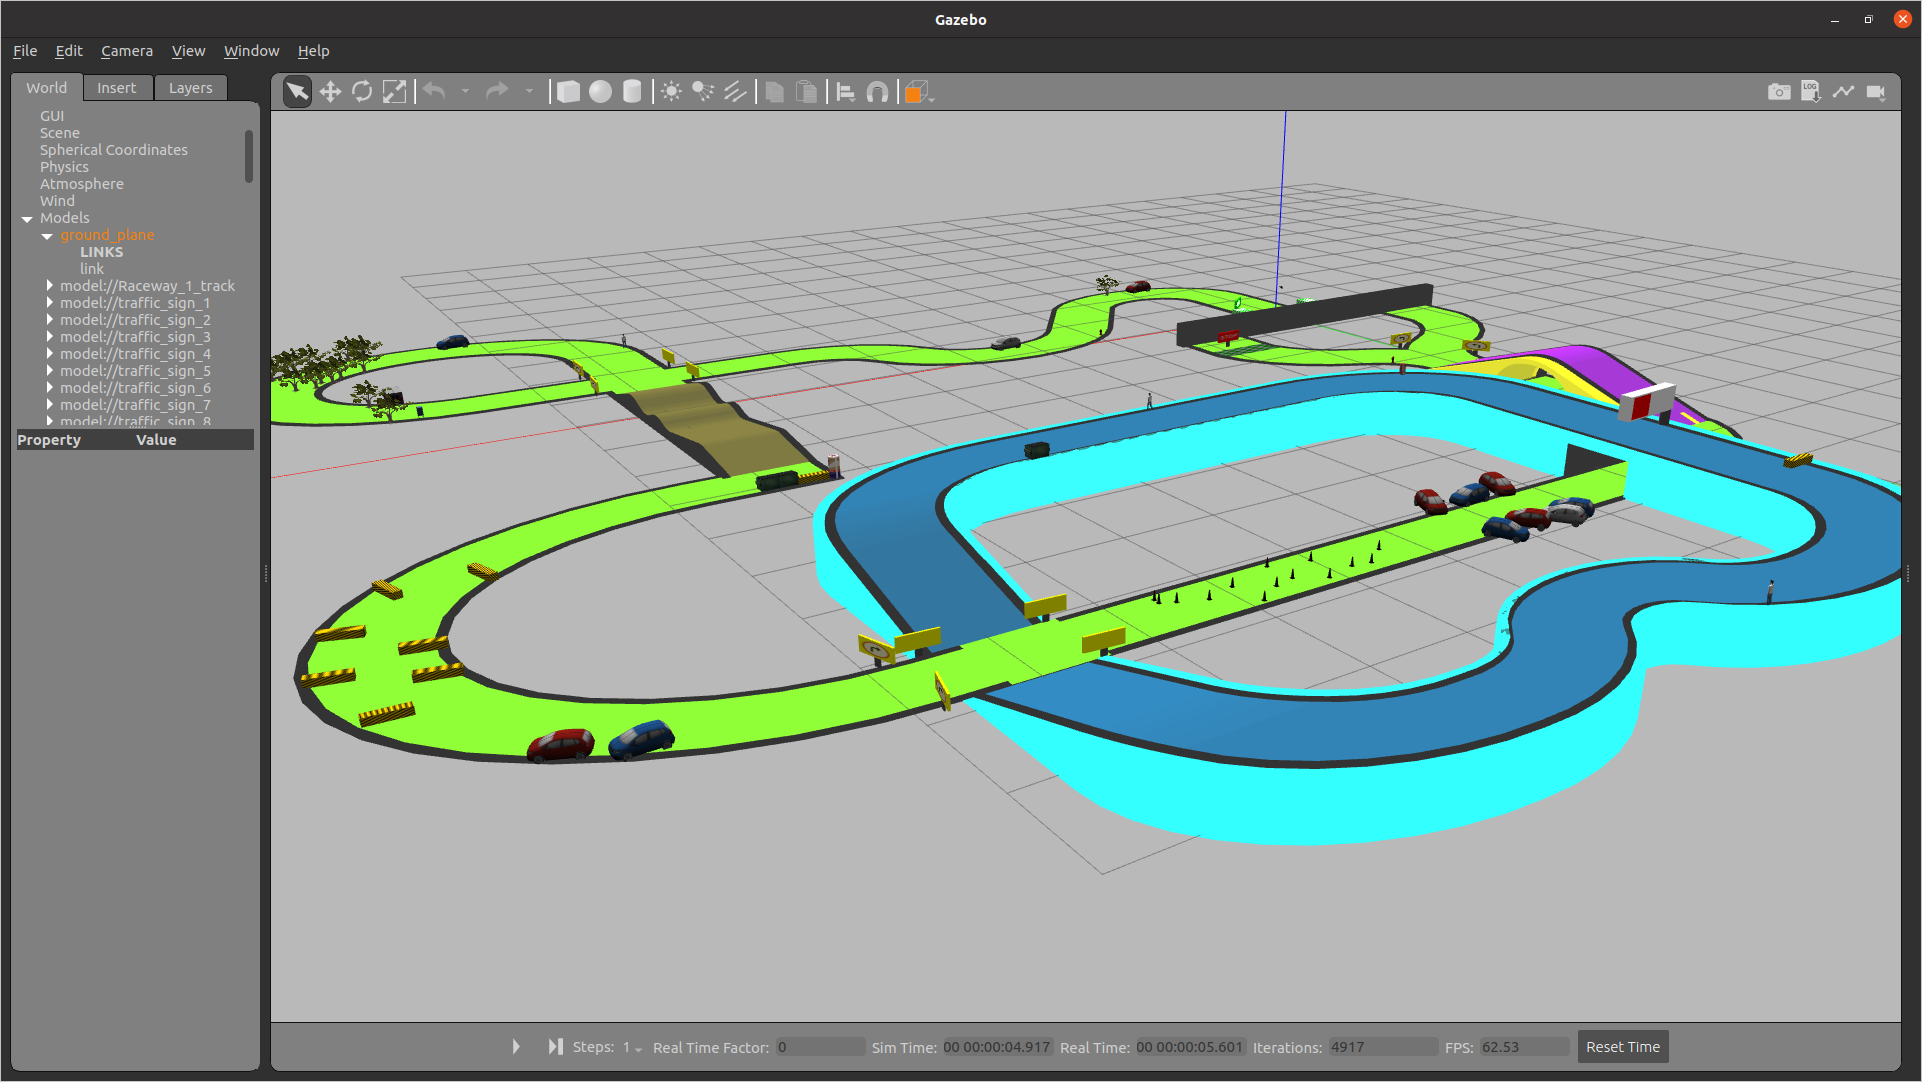
Deployed high-speed real-time planning and control algorithms in ROS 2/Gazebo for an autonomous racecar navigating dynamic traffic, elevation and realistic obstacle scenarios. Secured rank 2 out of 950+ teams and received the Best Coding Award.
Makerspace Lab, IIT Indore (TA & UG Coordinator)
Led hardware fabrication (PCB, CNC, laser cutting). Built autonomous solar-powered seed-sowing robot with embedded sensors. Mentored 200+ students in robotics, CV, CAD/CAM; established Tinkerer’s Lab course.
Designed and fabricated a VAWT combining Darrieus and Savonnius rotors with an auto-alignment blade control algorithm for maximum torque. Used CFD (Ansys Fluent) to analyze performance, validate design and optimize energy capture.
Fabrication, Simulation & Analysis of PUMA 560 Robot Arm
Developed PLA-based replica of PUMA560 robot arm. Conducted endurance, failure & torque analysis using Ansys Fluent.
Simulated kinematics in Webots with a factory demo environment.
FEM Project - Structural Behavior of Multi-Story Building Beams
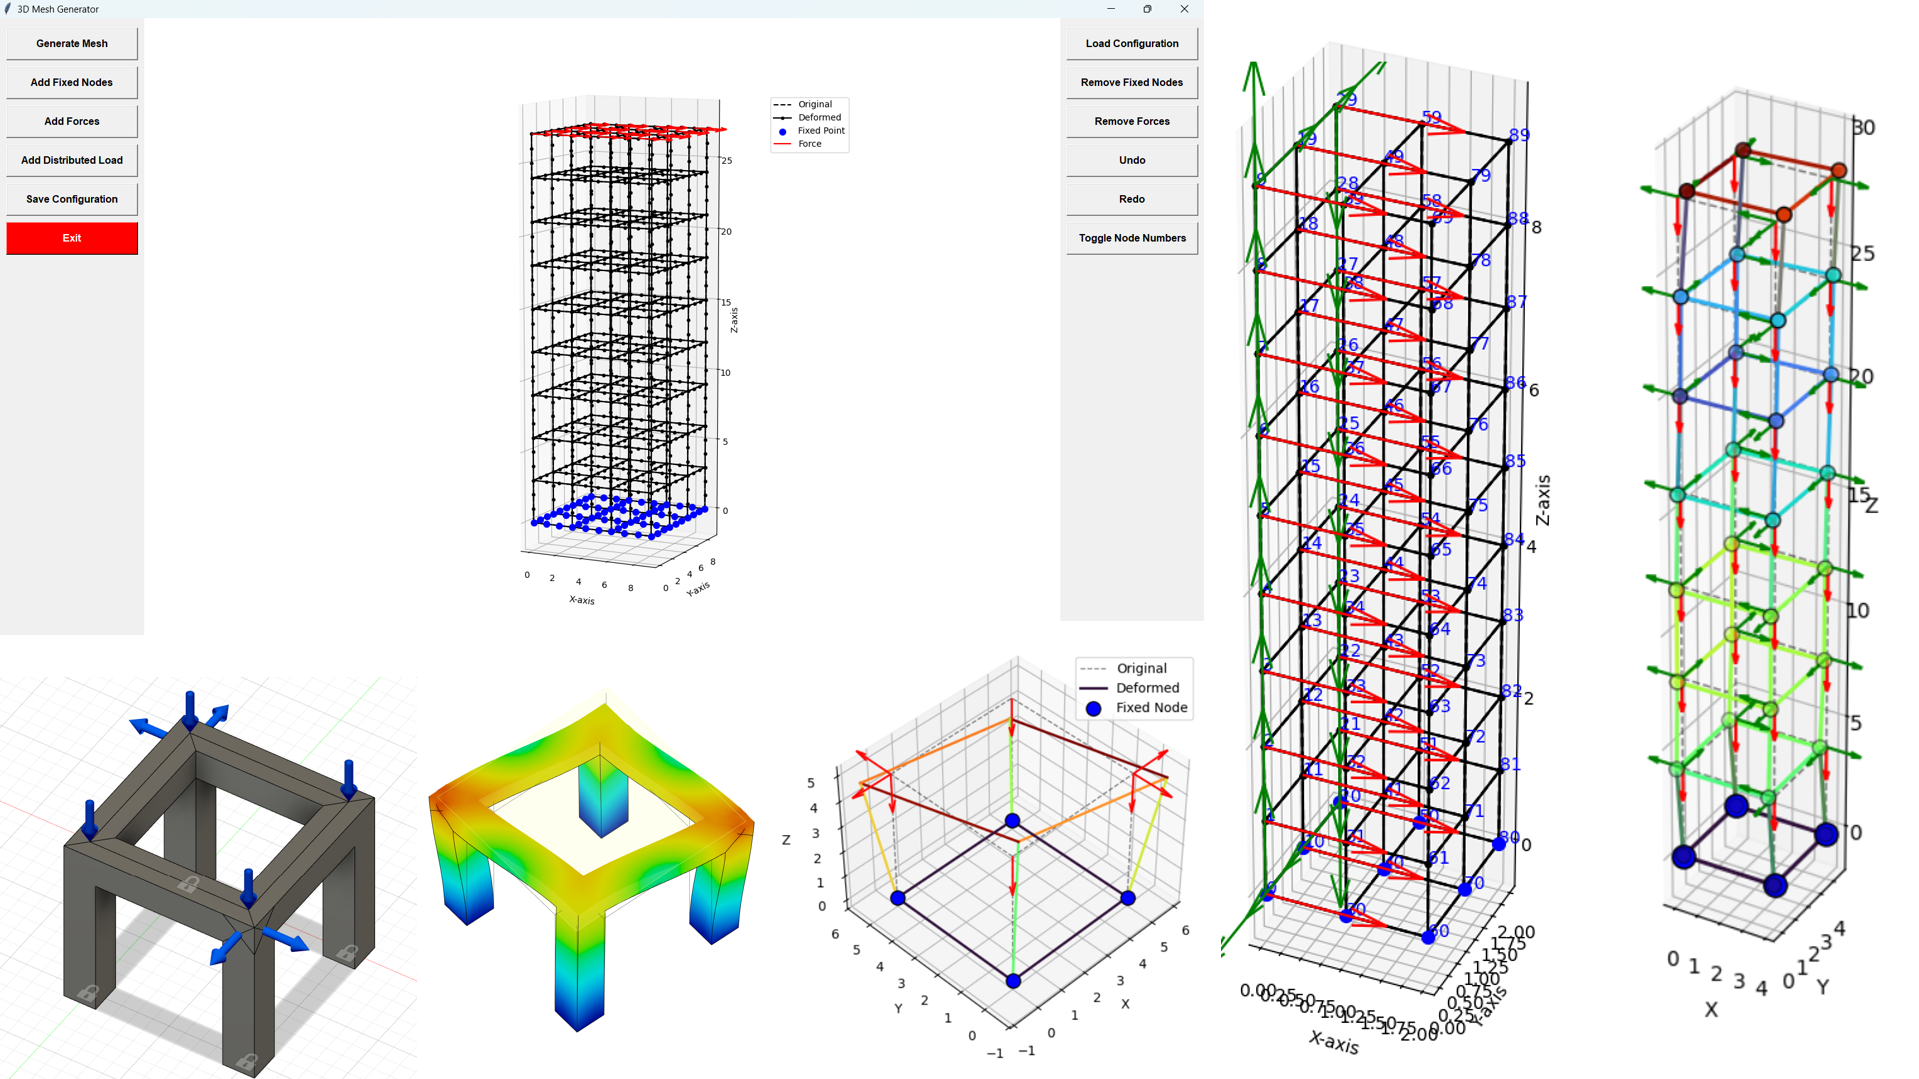
Implemented a custom 3D frame-element FEA tool (mesh generator, stiffness assembly) and validated displacements/stresses against Fusion 360 with an interactive post-processor for deformation, stress and factor of safety visualization.
Multi-Robot Coordination
Developed strategies for collaborative multi-robot systems.
Focused on coordination, localization and dynamic trajectory planning.
Computer Vision OCT Project
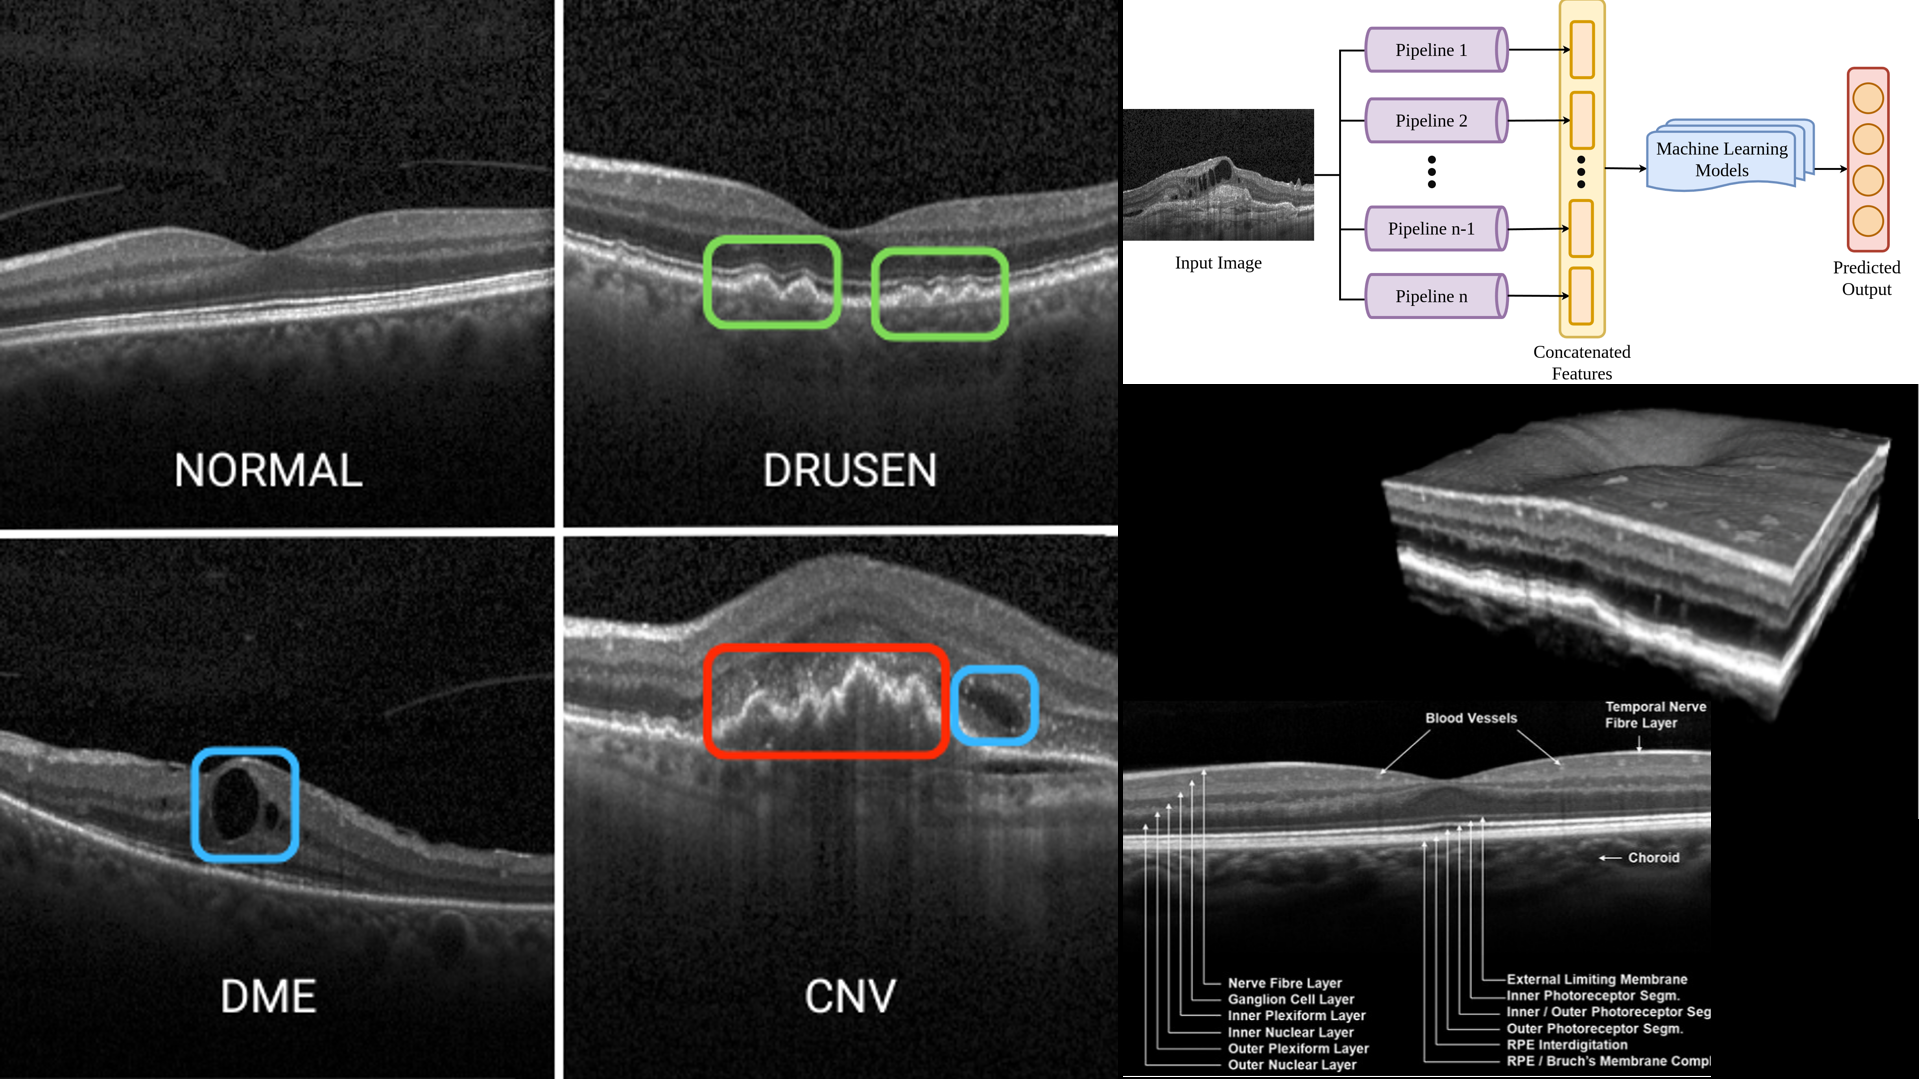
Designed an OCT classification pipeline using contour, texture, HOG and Fourier features with dimensionality reduction and classical ML models like SVM and XGBoost. Achieved ~90.9% accuracy on test data while ensuring efficiency and interpretability compared to deep learning baselines.
Academic History
Carnegie Mellon University
Aug 2025 - May 2027 | Pittsburgh, PA, USA
Pursuing M.S. in Robotic Systems Development | GPA: 4.17/4.0 Coursework: Robot Mobility(A+), Manipulation Estimation & Control(A+), Planning for Robotics, Systems Engineering. Ongoing: Robot Autonomy, Robot Localization and Mapping, MRSD Project, Intro to Robotics Business
Indian Institute of Technology Indore (IIT Indore)
Nov 2021 - July 2025 | Indore, India
B.Tech in Mechanical Engineering | GPA: 8.31/10 Coursework: Computer Vision, Spacecraft Attitude Dynamics, Control & Pointing, Kinematics & Dynamics of Machines.